Our mission is to help computational modelers develop, document, and share their computational models in accordance with community standards and good open science and software engineering practices. Model authors can publish their model source code in the Computational Model Library with narrative documentation as well as metadata that supports open science and emerging norms that facilitate software citation, computational reproducibility / frictionless reuse, and interoperability. Model authors can also request private peer review of their computational models. Models that pass peer review receive a DOI once published.
All users of models published in the library must cite model authors when they use and benefit from their code.
Please check out our model publishing tutorial and feel free to contact us if you have any questions or concerns about publishing your model(s) in the Computational Model Library.
Displaying 10 of 207 results for "Sharon Greene" clear search
AMBAWA, an Agent-based Model of Biomass flows in Agropastoral areas of West Africa
David Berre Christophe Le Page Tidiane Diarisso Nadine Andrieu Marc Corbeels François Bousquet Pablo Tittonell | Published Monday, November 23, 2015 | Last modified Sunday, April 12, 2020AMBAWA simulates the flows of biomass between crop and livestock systems at the field, farm, and village scales in order to showcase innovating management practices of soil fertility in West Africa.
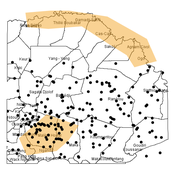
Agent-based modeling of the spatio-temporal distribution of Sahelian transhumant herds
Cheick Amed Diloma Gabriel TRAORE Etienne DELAY Alassane Bah Djibril Diop | Published Tuesday, May 20, 2025Sahelian transhumance is a seasonal pastoral mobility between the transhumant’s terroir of origin and one or more host terroirs. Sahelian transhumance can last several months and extend over hundreds of kilometers. Its purpose is to ensure efficient and inexpensive feeding of the herd’s ruminants. This paper describes an agent-based model to determine the spatio-temporal distribution of Sahelian transhumant herds and their impact on vegetation. Three scenarios based on different values of rainfall and the proportion of vegetation that can be grazed by transhumant herds are simulated. The results of the simulations show that the impact of Sahelian transhumant herds on vegetation is not significant and that rainfall does not impact the alley phase of transhumance. The beginning of the rainy season has a strong temporal impact on the spatial distribution of transhumant herds during the return phase of transhumance.
1984 social computation model
Harun Šiljak | Published Monday, September 30, 2019A system of nonlinear differential equations, modelled in MATLAB Simulink, simulating the world of George Orwell’s 1984.
Between Pleasure and Contentment: Evolutionary Dynamics of Some Possible Parameters of Happiness
Yue Gao Shimon Edelman | Published Saturday, March 12, 2016 | Last modified Wednesday, March 16, 2016We build a computational model to investigate, in an evolutionary setting, a series of questions pertaining to happiness.
Hedonic and Eudaimonic Well-being Based Reward for Intrinsic Motivated Reinforcement Learning Agents
Yue Gao Shimon Edelman | Published Monday, March 21, 2016The code contains four experiments for well-being based IMRL reward features.
Retail Competition Agent-based Model
Jiaxin Zhang Derek Robinson | Published Sunday, January 03, 2021 | Last modified Wednesday, November 10, 2021The Retail Competition Agent-based Model (RC-ABM) is designed to simulate the retail competition system in the Region of Waterloo, Ontario, Canada, which which explicitly represents store competition behaviour. Through the RC-ABM, we aim to answer 4 research questions: 1) What is the level of correspondence between market share and revenue acquisition for an agent-based approach compared to a traditional location-allocation-based approach? 2) To what degree can the observed store spatial pattern be reproduced by competition? 3) To what degree are their path dependent patterns of retail success? 4) What is the relationship between retail survival and the endogenous geographic characteristics of stores and consumer expenditures?
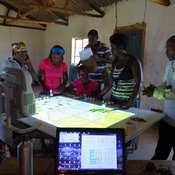
Kulayinjana
Christophe Le Page Arthur Perrotton Michel De Garine-Wichatitsky Barry Bitu Killion Koyisi Ferdinand Mwamba Cephus Ncube Victor Ncube Siphusisiwe Ndlovu Raphael Ngwenya Ambu Nyathi Fumbane Nyathi Patrick Sibanda Zenzo Sibanda | Published Monday, October 03, 2016a computer-based role-playing game simulating the interactions between farming activities, livestock herding and wildlife in a virtual landscape reproducing local socioecological dynamics at the periphery of Hwange National Park (Zimbabwe).
Institutional change
Abigail Sullivan | Published Friday, October 07, 2016 | Last modified Sunday, December 02, 2018This model builds on another model in this library (“diffusion of culture”).
Peer reviewed MOSAIC: Mission-Oriented Self-Organization through Auctions, Incentives, and Coalitions
Katherin Molina Lorena Holguin | Published Friday, July 31, 2026 | Last modified Thursday, August 20, 2026MOSAIC is an agent-based NetLogo model of decentralized mission coordination among heterogeneous robots operating under partial observability, limited energy, spatially variable risk, dynamic communication, and individual and cooperative task requirements. Robots discover tasks locally, exchange task information through temporary communication links, submit capability-, energy-, deadline-, and risk-aware bids, compete for individual contracts, and form temporary coalitions for cooperative tasks.
The model integrates decentralized auctions, greedy capability-based coalition formation, contract release and reassignment, four reward regimes, reputation, adaptive bidding strategies, failure traceability, and mission-, network-, information-, inequality-, and coalition-level metrics. It operates without a centralized mission planner or global combinatorial assignment solver.
Seven paired-seed BehaviorSpace experiments comprising 690 official simulation runs evaluate baseline mission viability, reward regimes, communication structure, capability heterogeneity, cooperative-task demand, reputation and adaptive strategies, and mission-incentive strength. The results indicate that structural coordination capacity—particularly information reach, capability compatibility, and feasible coalition construction—has a stronger effect on mission completion than increasing incentive intensity within the tested architecture and parameter ranges.
…
Firm explore-exploit of knowledge
Rosanna Garcia | Published Monday, March 28, 2011 | Last modified Saturday, April 27, 2013The basic premise of the model is to simulate several ‘agents’ going through build-buy cycles: Build: Factories follow simple rules of strategy in the allocation of resources between making exploration and exploitation type products. Buy: Each of two types of Consumers, early-adopters and late adopters, follow simple purchase decision rules in deciding to purchase a product from one of two randomly chosen factories. Thus, the two working ‘agents’ of the model are ‘factories’ and […]
Displaying 10 of 207 results for "Sharon Greene" clear search