Our mission is to help computational modelers develop, document, and share their computational models in accordance with community standards and good open science and software engineering practices. Model authors can publish their model source code in the Computational Model Library with narrative documentation as well as metadata that supports open science and emerging norms that facilitate software citation, computational reproducibility / frictionless reuse, and interoperability. Model authors can also request private peer review of their computational models. Models that pass peer review receive a DOI once published.
All users of models published in the library must cite model authors when they use and benefit from their code.
Please check out our model publishing tutorial and feel free to contact us if you have any questions or concerns about publishing your model(s) in the Computational Model Library.
Displaying 10 of 120 results for "Phesi Project" clear search
The Thin Blue Line Between Protesters and Their Counter-Protesters
Tamsin Lee | Published Monday, March 26, 2018More frequently protests are accompanied by an opposing group performing a counter protest. This phenomenon can increase tension such that police must try to keep the two groups separated. However, what is the best strategy for police? This paper uses a simple agent-based model to determine the best strategy for keeping the two groups separated. The ‘thin blue line’ varies in density (number of police), width and the keenness of police to approach protesters. Three different groups of protesters are modelled to mimic peaceful, average and volatile protests. In most cases, a few police forming a single-file ‘thin blue line’ separating the groups is very effective. However, when the protests are more volatile, it is more effective to have many police occupying a wide ‘thin blue line’, and police being keen to approach protesters. To the authors knowledge, this is the first paper to model protests and counter-protests.
A model of urban expansion policy scenarios using an agent-based approach—a case of the Guangzhou Metropolitan Region of China
Guangjin Tian | Published Friday, March 21, 2014Three policy scenarios for urban expansion under the influences of the behaviours and decision modes of four agents and their interactions have been applied to predict the future development patterns of the Guangzhou metropolitan region.
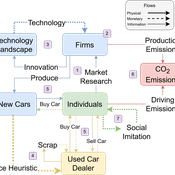
Driving in the wrong direction? Modelling policy mixes for EV adoption
Daniel Torren-Peraire | Published Friday, July 11, 2025 | Last modified Wednesday, August 05, 2026Car-centric societies face challenges in transitioning to sustainable mobility,
with electric vehicle adoption depending on the interaction of consumer behaviour,
firm innovation, and policy incentives. To examine these dynamics, we develop an
agent-based model calibrated on California data from 2001–2023. Heterogeneous
consumers influence each other in their acceptance of EVs, while manufacturers
incorporate these changes into their innovation and product-mix strategies. We
…
The emergence of new market logics in sustainable food
César García-Díaz | Published Friday, October 30, 2026The model represents a large, traditional firm competing with small, sustainable food producers. The large firm operates under conventional assumptions, pursuing monopoly profits maximized through standard economic principles. Its behavior is driven by economies of scale, which compel small firms to strategically differentiate themselves to deliver added value to consumers. Consequently, small firms focus on offering higher-quality products—a factor that matters significantly to consumers.
The gains achieved by small firms represent social profits that hinge upon establishing co-participation schemes with farmers and building trustworthy relationships with consumers. Cooperation with farmers directly shapes production processes and product quality. Because a firm trusted by one consumer becomes visible to neighbors, trust can diffuse and evolve into a collective identity. Ultimately, population-level legitimation occurs when the organizational form of the organic food producer gains widespread acceptance within the consumer community.
The model’s behavior depends on three key factors: a trust parameter, a legitimation intensity parameter, and an aspiration-level weight (for the large firm).
Sensitivity of a population submitted to floods to unknown upcoming floods and parameters of the dynamics
Sylvie Huet | Published Wednesday, September 22, 2021This work is a java implementation of a study of the viability of a population submitted to floods. The population derives some benefit from living in a certain environment. However, in this environment, floods can occur and cause damage. An individual protection measure can be adopted by those who wish and have the means to do so. The protection measure reduces the damage in case of a flood. However, the effectiveness of this measure deteriorates over time. Individual motivation to adopt this measure is boosted by the occurrence of a flood. Moreover, the public authorities can encourage the population to adopt this measure by carrying out information campaigns, but this comes at a cost. People’s decisions are modelled based on the Protection Motivation Theory (Rogers1975, Rogers 1997, Maddux1983) arguing that the motivation to protect themselves depends on their perception of risk, their capacity to cope with risk and their socio-demographic characteristics.
While the control designing proper informations campaigns to remain viable every time is computed in the work presented in https://www.comses.net/codebases/e5c17b1f-0121-4461-9ae2-919b6fe27cc4/releases/1.0.0/, the aim of the present work is to produce maps of probable viability in case the serie of upcoming floods is unknown as well as much of the parameters for the population dynamics. These maps are bi-dimensional, based on the value of known parameters: the current average wealth of the population and their actual or possible future annual revenues.
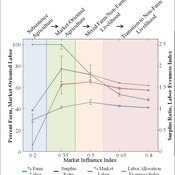
Land-Livelihood Transitions
Nicholas Magliocca Daniel G Brown Erle C Ellis | Published Monday, September 09, 2013 | Last modified Friday, September 13, 2013Implemented as a virtual laboratory, this model explores transitions in land-use and livelihood decisions that emerge from changing local and global conditions.
Micro-level Adaptation, Macro-level Selection, and the Dynamics of Market Partitioning
César García-Díaz | Published Monday, October 19, 2015 | Last modified Monday, October 19, 2015This model simulates the emergence of a dual market structure from firm-level interaction. Firms are profit-seeking, and demand is represented by a unimodal distribution of consumers along a set of taste positions.
Simulating the cost of social care in an ageing population
Eric Silverman | Published Thursday, September 16, 2021This model is an agent-based simulation written in Python 2.7, which simulates the cost of social care in an ageing UK population. The simulation incorporates processes of population change which affect the demand for and supply of social care, including health status, partnership formation, fertility and mortality. Fertility and mortality rates are drawn from UK population data, then projected forward to 2050 using the methods developed by Lee and Carter 1992.
The model demonstrates that rising life expectancy combined with lower birthrates leads to growing social care costs across the population. More surprisingly, the model shows that the oft-proposed intervention of raising the retirement age has limited utility; some reductions in costs are attained initially, but these reductions taper off beyond age 70. Subsequent work has enhanced and extended this model by adding more detail to agent behaviours and familial relationships.
The version of the model provided here produces outputs in a format compatible with the GEM-SA uncertainty quantification software by Kennedy and O’Hagan. This allows sensitivity analyses to be performed using Gaussian Process Emulation.
Space colonization
allagonne | Published Wednesday, January 05, 2022Agent-Based-Modeling - space colonization
ask me for the .nlogo model
WHAT IS IT?
The goal of this project is to simulate with NetLogo (v6.2) a space colonization of humans, starting from Earth, into the Milky Way.
HOW IT WORKS
…
Amber Dilemma Zone: Driver Cognition and Signal Control in Urban Traffic
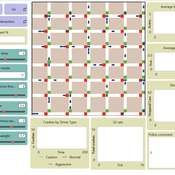
Mansoor Abdul Bari | Published Sunday, July 19, 2026This model is an extension of Wilensky’s (2003) Traffic Grid, a foundational NetLogo model of urban traffic flow. It embeds a dual-process cognitive architecture into each driver agent, transforming the original’s identical reactive units into cognitively heterogeneous individuals whose internal mental state evolves with experience; making the same intersection produce different decisions from different drivers, and different decisions from the same driver across occasions.
The core question the model addresses is the yellow-light dilemma zone: the seconds following amber onset in which a driver can neither stop safely nor clear the intersection before red. Field research documents that behavioral variance at this moment cannot be explained by geometry or legal obligation alone. This model provides the cognitive architecture that has been missing from traffic ABMs.
Each driver routes every amber-onset decision through either System 1 (fast, heuristic, automatic) or System 2 (slow, deliberative, prospect-theoretic), switching dynamically based on cognitive load, accumulated near-miss memory, and situational framing. The result is crash outcomes that are attributable, path-dependent, and sensitive to both driver disposition and signal infrastructure; none of which fixed-rule models can reproduce. Three signal control modes are included: fixed-cycle (replicating Wilensky’s original), adaptive-queue, and smart occupancy-based switching.
Displaying 10 of 120 results for "Phesi Project" clear search