Our mission is to help computational modelers develop, document, and share their computational models in accordance with community standards and good open science and software engineering practices. Model authors can publish their model source code in the Computational Model Library with narrative documentation as well as metadata that supports open science and emerging norms that facilitate software citation, computational reproducibility / frictionless reuse, and interoperability. Model authors can also request private peer review of their computational models. Models that pass peer review receive a DOI once published.
All users of models published in the library must cite model authors when they use and benefit from their code.
Please check out our model publishing tutorial and feel free to contact us if you have any questions or concerns about publishing your model(s) in the Computational Model Library.
Displaying 10 of 144 results for "Daniel G Brown" clear search
Cliff Walking with Q-Learning NetLogo Extension
Kevin Kons Fernando Santos | Published Tuesday, December 10, 2019This model implements a classic scenario used in Reinforcement Learning problem, the “Cliff Walking Problem”. Consider the gridworld shown below (SUTTON; BARTO, 2018). This is a standard undiscounted, episodic task, with start and goal states, and the usual actions causing movement up, down, right, and left. Reward is -1 on all transitions except those into the region marked “The Cliff.” Stepping into this region incurs a reward of -100 and sends the agent instantly back to the start (SUTTON; BARTO, 2018).
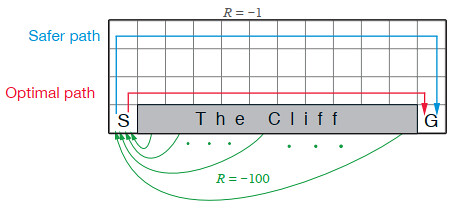
The problem is solved in this model using the Q-Learning algorithm. The algorithm is implemented with the support of the NetLogo Q-Learning Extension
Learning Extension - RAGE RAngeland Grazing Model
Cristina I. Apetrei Nikita Strelkovskii Nikolay Khabarov Valeria Javalera Rincón | Published Saturday, July 22, 2023This is an extension of the original RAGE model (Dressler et al. 2018), where we add learning capabilities to agents, specifically learning-by-doing and social learning (two processes central to adaptive (co-)management).
The extension module is applied to smallholder farmers’ decision-making - here, a pasture (patch) is the private property of the household (agent) placed on it and there is no movement of the households. Households observe the state of the pasture and their neighrbours to make decisions on how many livestock to place on their pasture every year. Three new behavioural types are created (which cannot be combined with the original ones): E-RO (baseline behaviour), E-LBD (learning-by-doing) and E-RO-SL1 (social learning). Similarly to the original model, these three types can be compared regarding long-term social-ecological performance. In addition, a global strategy switching option (corresponding to double-loop learning) allows users to study how behavioural strategies diffuse in a heterogeneous population of learning and non-learning agents.
An important modification of the original model is that extension agents are heterogeneous in how they deal with uncertainty. This is represented by an agent property, called the r-parameter (household-risk-att in the code). The r-parameter is catch-all for various factors that form an agent’s disposition to act in a certain way, such as: uncertainty in the sensing (partial observability of the resource system), noise in the information received, or an inherent characteristic of the agent, for instance, their risk attitude.
Mobility Sharing for Social Integration: A Reverse Schelling Model
Hongmou Zhang | Published Thursday, October 15, 2026This model extends Schelling’s segregation model with mobility sharing. Agents of two groups occupy cells of a 32 × 32 grid and repeatedly choose activity destinations subject to a preference threshold, the minimum share of ingroup neighbours they accept. Trips are matched into shared rides between members of different groups, using one of four matching algorithms on a shareability network (maximal cross-group matching, maximum weight matching on contact time, maximum cardinality matching, or random greedy matching) with a maximum detour constraint. After each trip, an agent’s preference threshold changes with the time spent in contact with outgroup members.
Starting from complete segregation, the model examines under which conditions contact during shared trips leads to integration. Besides the main scenario, in which contact always lowers the threshold, it includes two extensions. In the first, a share of adversarial agents becomes less tolerant with contact, and this share grows or shrinks with the current level of segregation, governed by a branching dissimilarity index and a conversion rate. In the second, each contact raises or lowers the threshold with a probability that depends on the agent’s current attitude relative to a compatibility threshold.
Segregation is measured with the index of dissimilarity and the Gini coefficient. The model file includes BehaviorSpace experiments for each analysis in the associated article. The matching step uses the NetworkX library through the Python extension of NetLogo (requires Python 3 with numpy and networkx 3.x).
Peer reviewed A model of environmental awareness spread and its effect in resource consumption reduction
Giovanna Sissa | Published Sunday, June 21, 2015 | Last modified Monday, August 17, 2015The model reproduces the spread of environmental awareness among agents and the impact of awareness level of the agents on the consumption of a resource, like energy. An agent is a household with a set of available advanced smart metering functions.
Peer reviewed Collective Problem-Solving Capacity, Trust, and O-Ring Team Productivity
Taseer Salahuddin Hasan Vergil Muhammad Abdullah Yasser | Published Saturday, August 08, 2026This is a NetLogo 7.0.1 agent-based model of interdependent team productivity under O-ring production logic. The model asks when collective problem-solving capacity (CPS) improves team output and when its effect is constrained by trust, burnout, specialization diversity, weak-link quality, and team-formation rules. Agents are heterogeneous in skill, CPS, trust, burnout, effort, learning rate, openness, specialization, adaptability, and aspiration. Each tick forms temporary teams, computes individual contribution quality, combines contributions through a geometric O-ring production function with an explicit weakest-link term, records output and success, and updates agents through feedback, learning, trust change, burnout, recovery, and turnover. The paper follows the ODD protocol, reports exact implementation equations, and analyzes six BehaviorSpace experiments with 50 stochastic repetitions per condition. Scenario results show that CPS is beneficial but not sufficient: productivity is highest when CPS is combined with trust, low burnout, effective coordination, and a reliable weakest-link floor. Diversity yields only modest gains at low CPS but larger gains when CPS is high. Formation-mode results are especially informative because mixed CPS-skill formation maximizes total output, whereas random formation has the highest binary success rate, showing that output magnitude and threshold success can diverge. The study contributes a transparent computational mechanism linking collective intelligence with O-ring production and identifies boundary conditions under which high-CPS teams can still be limited by weak links and interdependence.
Artificial Anasazi: Baseline Fixes, Dynamic Soil and Plot Crowding
Thomas Tuoti | Published Sunday, October 04, 2026Artificial Anasazi is an agent-based model of farming households in the Long House Valley, Arizona, from 800 to 1350 CE. Each household chooses where to farm and settle based on expected harvest, water sources and stored maize, and simulated household counts are compared with the archaeological record.
This release adapts the NetLogo Models Library version (Stonedahl & Wilensky 2010) of Janssen’s (2009) NetLogo replication of the original Ascape model (Dean et al. 2000; Axtell et al. 2002). It contains four configurations in one NetLogo 7.0.4 file, selected with two switches:
- Both switches off: the baseline, which is the Models Library model with small fixes that make it work as intended (the arable-uplands zone name, the setup base yield, the initial household count, one-tick-lag capacity reporting, and seed control with observation-only instruments).
soil-on?: dynamic soil quality that depletes under cultivation and regrows, following Janssen (2010, eq. 4).
…
AMIRIS
Kristina Nienhaus Christoph Schimeczek Ulrich Frey Evelyn Sperber Seyedfarzad Sarfarazi Felix Nitsch Johannes Kochems Aboubakr Achraf El Ghazi | Published Thursday, February 03, 2022AMIRIS is the Agent-based Market model for the Investigation of Renewable and Integrated energy Systems.
It is an agent-based simulation of electricity markets and their actors.
AMIRIS enables researches to analyse and evaluate energy policy instruments and their impact on the actors involved in the simulation context.
Different prototypical agents on the electricity market interact with each other, each employing complex decision strategies.
AMIRIS allows to calculate the impact of policy instruments on economic performance of power plant operators and marketers.
…
Viking Sailing: Simulation of Viking era small ship sailing
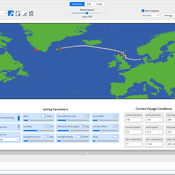
C Michael Barton | Published Wednesday, October 07, 2026Viking Sailing is a spatially explicit agent-based simulation for conditional exploration of how rasterized coastlines, wind, and
surface-current conditions interact with simplified ship movement, sailing, rowing, navigation, and land-avoidance rules. The
model compares simulated route trajectories and terminal outcomes for hypothetical Viking-era small-ship voyages. It includes an example dataset representing sea surface winds and currents from June 1000 CE. Additional data can are downloaded from Zenodo: https://zenodo.org/records/23213147.
Observer Zero: an instrumented artificial world for studying scientific belief revision in autonomous LLM agents
Nick Lamb | Published Thursday, August 13, 2026Meridian is a deterministic artificial world in which autonomous LLM scientist agents run
experiments on instruments, exchange letters, and maintain explicit probabilistic beliefs, while
a physical constant changes covertly mid-run. The true state is known only to the simulator, so
whether anyone notices becomes a measurement rather than an interpretation.
The platform separates three things that are usually confounded: what could have been known from
…
FlowLogo for a real case study
Vahid Aghaie | Published Monday, May 18, 2020Juan Castilla-Rho et al. (2015) developed a platform, named FLowLogo, which integrates a 2D, finite-difference solution of the governing equations of groundwater flow with agent-based simulation. We used this model for Rafsanjan Aquifer, which is located in an arid region in Iran. To use FLowLogo for a real case study, one needs to add GIS shapefiles of boundary conditions and modify the code written in NetLogo a little bit. The FlowLogo model used in our research is presented here.
Displaying 10 of 144 results for "Daniel G Brown" clear search