Our mission is to help computational modelers develop, document, and share their computational models in accordance with community standards and good open science and software engineering practices. Model authors can publish their model source code in the Computational Model Library with narrative documentation as well as metadata that supports open science and emerging norms that facilitate software citation, computational reproducibility / frictionless reuse, and interoperability. Model authors can also request private peer review of their computational models. Models that pass peer review receive a DOI once published.
All users of models published in the library must cite model authors when they use and benefit from their code.
Please check out our model publishing tutorial and feel free to contact us if you have any questions or concerns about publishing your model(s) in the Computational Model Library.
Displaying 10 of 1017 results for "Jan Van Bavel" clear search
Correlated random walk
Thibault Fronville | Published Friday, April 01, 2022 | Last modified Monday, April 25, 2022The first simple movement models used unbiased and uncorrelated random walks (RW). In such models of movement, the direction of the movement is totally independent of the previous movement direction. In other words, at each time step the direction, in which an individual is moving is completely random. This process is referred to as a Brownian motion.
On the other hand, in correlated random walks (CRW) the choice of the movement directions depends on the direction of the previous movement. At each time step, the movement direction has a tendency to point in the same direction as the previous one. This movement model fits well observational movement data for many animal species.
The presented agent based model simulated the movement of the agents as a correlated random walk (CRW). The turning angle at each time step follows the Von Mises distribution with a ϰ of 10. The closer ϰ gets to zero, the closer the Von Mises distribution becomes uniform. The larger ϰ gets, the more the Von Mises distribution approaches a normal distribution concentrated around the mean (0°).
This model is implemented in python and can be used as a building block for more complex agent based models that would rely on describing the movement of individuals with CRW.
We construct a new type of agent-based model (ABM) that can simultaneously simulate land-use changes at multiple distant places (namely TeleABM, telecoupled agent-based model). We use soybean trade between Brazil and China as an example, where Brazil is the sending system and China is the receiving system because they are the world’s largest soybean exporter and importer respectively. We select one representative county in each country to calibrate and validate the model with spatio-temporal analysis of historical land-use changes and the empirical analysis of household survey data. The whole model is programmed on RePast Simphony. The most unique features of TeleABM are that it can simulate a telecoupled system and the flows between sending and receiving systems in this telecoupled system.
Transport simulation in a real road network
Jiaqi Ge Gary Polhill | Published Tuesday, April 17, 2018 | Last modified Tuesday, April 17, 2018Ge, J., & Polhill, G. (2016). Exploring the Combined Impact of Factors Influencing Commuting Patterns and CO2 Emission in Aberdeen Using an Agent-Based Model. Journal of Artificial Societies and Social Simulation, 19(3). http://jasss.soc.surrey.ac.uk/19/3/11.html
We develop an agent-based transport model using a realistic GIS-enabled road network and the car following method. The model can be used to study the impact of social interventions such as flexi-time and workplace sharing, as well as large infrastructure such as the construction of a bypass or highway. The model is developed in Netlogo version 5 and requires road network data in GIS format to run.
The Effect of Merger and Acquisitions on the IS Function: An Agent Based Simulation Model
Andrea Genovese | Published Tuesday, June 23, 2009 | Last modified Saturday, April 27, 2013Merger and acquisition (M&A) activity has many strategic and operational objectives. One operational objective is to develop common and efficient information systems that maybe the source of creating
The Evolution of Multiple Resistant Strains: An Abstract Model of Systemic Treatment and Accumulated Resistance
Benjamin Nye | Published Wednesday, August 31, 2011 | Last modified Saturday, April 27, 2013This model is intended to explore the effectiveness of different courses of interventions on an abstract population of infections. Illustrative findings highlight the importance of the mechanisms for variability and mutation on the effectiveness of different interventions.
SimDrink: An agent-based NetLogo model of young, heavy drinkers for conducting alcohol policy experiments
Nick Scott Michael Livingston Aaron Hart James Wilson David Moore Paul Dietze | Published Friday, September 25, 2015 | Last modified Thursday, October 15, 2015A proof-of-concept agent-based model ‘SimDrink’, which simulates a population of 18-25 year old heavy alcohol drinkers on a night out in Melbourne to provide a means for conducting policy experiments to inform policy decisions.
An agent-based model to simulate the impact of developers’ capital possession on urban development
Agung Wahyudi | Published Saturday, June 23, 2018The model combines agent-based modelling and microeconomic approach to simulate the decision behaviour of land developers and how this impacts on the spatio-temporal processes of urban expansion.
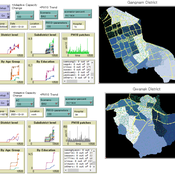
An Agent-based Assessment of Health Vulnerability to Long-term particulate exposure in Seoul Districts
Hyesop Shin Mike Bithell | Published Monday, November 05, 2018 | Last modified Monday, December 03, 2018This model aims to understand the cumulative effects on the population’s vulnerability as represented by exposure to PM10 (particulate matter with diameter less than 10 micrometres) by different age and educational groups in two Seoul districts, Gangnam and Gwanak. Using this model, readers can explore individual’s daily commuting routine, and its health loss when the PM10 concentration of the current patch breaches the national limit of 100µg/m3.
An Agent-Based Model of Insurance Customer Behaviour with Word of Mouth Network in C#
Rei England Iqbal Owadally Douglas Wright | Published Friday, March 04, 2022This is an agent-based model with two types of agents: customers and insurers. Insurers are price-takers who choose how much to spend on their service quality, and customers evaluate insurers based on premium, brand preference, and their perceived service quality. Customers are also connected in a small-world network and may share their opinions with their network.
The ABM contains two types of agents: insurers and customers. These act within the environment of a motor insurance market. At each simulation, the model undergoes the following steps:
- Network generation: At the start of the simulation, the model generates a small world network of social links between the customers, and randomly assigns each customer to an initial insurer ...
Confirmation Bias improves Performance in a Signal Detection Task and evolves in an Evolutionary Algorithm
Michael Vogrin | Published Monday, May 08, 2023Confirmation Bias is usually seen as a flaw of the human mind. However, in some tasks, it may also increase performance. Here, agents are confronted with a number of binary Signals (A, or B). They have a base detection rate, e.g. 50%, and after they detected one signal, they get biased towards this type of signal. This means, that they observe that kind of signal a bit better, and the other signal a bit worse. This is moderated by a variable called “bias_effect”, e.g. 10%. So an agent who detects A first, gets biased towards A and then improves its chance to detect A-signals by 10%. Thus, this agent detects A-Signals with the probability of 50%+10% = 60% and detects B-Signals with the probability of 50%-10% = 40%.
Given such a framework, agents that have the ability to be biased have better results in most of the scenarios.
Displaying 10 of 1017 results for "Jan Van Bavel" clear search