Our mission is to help computational modelers develop, document, and share their computational models in accordance with community standards and good open science and software engineering practices. Model authors can publish their model source code in the Computational Model Library with narrative documentation as well as metadata that supports open science and emerging norms that facilitate software citation, computational reproducibility / frictionless reuse, and interoperability. Model authors can also request private peer review of their computational models. Models that pass peer review receive a DOI once published.
All users of models published in the library must cite model authors when they use and benefit from their code.
Please check out our model publishing tutorial and feel free to contact us if you have any questions or concerns about publishing your model(s) in the Computational Model Library.
Displaying 10 of 321 results for "Martin Lange" clear search
ForagerNet3_Demography: A Non-Spatial Model of Hunter-Gatherer Demography
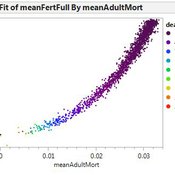
Andrew White | Published Thursday, October 17, 2013 | Last modified Thursday, October 17, 2013ForagerNet3_Demography is a non-spatial ABM for exploring hunter-gatherer demography. Key methods represent birth, death, and marriage. The dependency ratio is an imporant variable in many economic decisions embedded in the methods.
ForagerNet3_Demography_V2
Andrew White | Published Thursday, February 13, 2014ForagerNet3_Demography_V2 is a non-spatial ABM for exploring hunter-gatherer demography. This version (developed from FN3D_V1) contains code for calculating the ratio of old to young adults (the “OY ratio”) in the living and dead populations.
Peer reviewed COMMAND-AND-CONTROL
Farzaneh Davari | Published Tuesday, September 10, 2019 | Last modified Thursday, September 12, 2019The command and control policy in natural resource management, including water resources, is a longstanding established policy that has been theoretically and practically argued from the point of view of social-ecological complex systems. With the intention of making a system ecologically resilient, these days, policymakers apply the top-down policies of controlling communities through regulations. To explore how these policies may work and to understand whether the ecological goal can be achieved via command and control policy, this research uses the capacity of Agent-Based Modeling (ABM) as an experimental platform in the Urmia Lake Basin (ULB) in Iran, which is a social-ecological complex system and has gone through a drought process.
Despite the uncertainty of the restorability capacity of the lake, there has been a consensus on the possibility to artificially restore the lake through the nationally managed Urmia Lake Restoratoin Program (ULRP). To reduce water consumption in the Basin, the ULRP widely targets the agricultural sector and proposes the project of changing crop patterns from high-water-demand (HWD) to low-water-demand (LWD), which includes a component to control water consumption by establishing water-police forces.
Using a wide range of multidisciplinary studies about Urmia Lake at the Basin and sub-basins as well as qualitative information at micro-level as the main conceptual sources for the ABM, the findings under different strategies indicate that targeting crop patterns change by legally limiting farmers’ access to water could force farmers to change their crop patterns for a short period of time as long as the number of police constantly increases. However, it is not a sustainable policy for either changing the crop patterns nor restoring the lake.
One Signal, Many Feeds: An Empirical-Response Agent-Based Model of Coordination Failure in Algorithmic Creator Discovery
Haocheng Wang | Published Thursday, August 06, 2026An empirical-response agent-based model of how many personalized feeds execute a shared low-exposure creator-discovery objective. Built from the KuaiRec dataset: the big interaction matrix initializes a transparent rank-8 matrix-factorization platform learner and the activity schedule, while the near-complete small matrix returns observed viewing responses only after a user-video pair is exposed. Four exploration policies (synchronous low-exposure targeting, uniform exploration, per-user random tie-breaking, capacity-balanced coordination) are compared over 28 rounds at a nominal 10% exploration budget, across 30 paired seeds (core) and 10 paired seeds (bias-only probe), with slot-level redundancy, cross-user collision, and coverage diagnostics.
This release accompanies an anonymised manuscript under review at the Journal of Artificial Societies and Social Simulation.
The model represents 1,411 users, 3,327 videos, 2,031 authors, and an adaptive platform over 28 discrete rounds derived from the KuaiRec big-matrix activity calendar. Exploration policies differ only in how a fixed 10% slot budget is allocated; all policies share the opportunity schedule, response oracle, initial checkpoints, and online update rule.
Archive contents: analysis pipeline scripts (01-16), frozen machine-readable protocols with input hashes, initial model checkpoints, aggregate result tables, the complete ODD protocol record, and publication figures. Raw KuaiRec files are not redistributed; obtain them from the official dataset repository and verify against the input hashes in data_contract/. Row-level oracle tables are excluded by design.
…
Peer reviewed Emergence of Organizations out of Garbage Can Dynamics
Guido Fioretti | Published Monday, April 20, 2020 | Last modified Sunday, April 26, 2020The Garbage Can Model of Organizational Choice (GCM) is a fundamental model of organizational decision-making originally propossed by J.D. Cohen, J.G. March and J.P. Olsen in 1972. In their model, decisions are made out of random meetings of decision-makers, opportunities, solutions and problems within an organization.
With this model, these very same agents are supposed to meet in society at large where they make decisions according to GCM rules. Furthermore, under certain additional conditions decision-makers, opportunities, solutions and problems form stable organizations. In this artificial ecology organizations are born, grow and eventually vanish with time.
A Simple Agent Based Modeling Tool for Plastic and Debris Tracking in Oceans
Subu Kandaswamy Koushik Sura Bhaskar Sai Amulya Murukutla Sai Pranay Raju Chinthala Abhishek Bobbillapati | Published Monday, October 04, 2021Plastics and the pollution caused by their waste have always been a menace to both nature and humans. With the continual increase in plastic waste, the contamination due to plastic has stretched to the oceans. Many plastics are being drained into the oceans and rose to accumulate in the oceans. These plastics have seemed to form large patches of debris that keep floating in the oceans over the years. Identification of the plastic debris in the ocean is challenging and it is essential to clean plastic debris from the ocean. We propose a simple tool built using the agent-based modeling framework NetLogo. The tool uses ocean currents data and plastic data both being loaded using GIS (Geographic Information System) to simulate and visualize the movement of floatable plastic and debris in the oceans. The tool can be used to identify the plastic debris that has been piled up in the oceans. The tool can also be used as a teaching aid in classrooms to bring awareness about the impact of plastic pollution. This tool could additionally assist people to realize how a small plastic chunk discarded can end up as large debris drifting in the oceans. The same tool might help us narrow down the search area while looking out for missing cargo and wreckage parts of ships or flights. Though the tool does not pinpoint the location, it might help in reducing the search area and might be a rudimentary alternative for more computationally expensive models.
The AgriculTural LandscApe Simulator (ATLAS)
Hugo Thierry Claude Monteil Aude Vialatte Jean-Philippe Choisis Benoit Gaudou Hazel Parry | Published Monday, January 30, 2017 | Last modified Wednesday, May 10, 2017The spatially-explicit AgriculTuralLandscApe Simulator (ATLAS) simulates realistic spatial-temporal crop availability at the landscape scale through crop rotations and crop phenology.
Transport simulation in a real road network
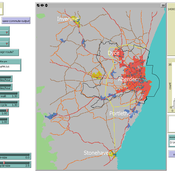
Gary Polhill Jiaqi Ge | Published Tuesday, April 17, 2018 | Last modified Tuesday, April 17, 2018Ge, J., & Polhill, G. (2016). Exploring the Combined Impact of Factors Influencing Commuting Patterns and CO2 Emission in Aberdeen Using an Agent-Based Model. Journal of Artificial Societies and Social Simulation, 19(3). http://jasss.soc.surrey.ac.uk/19/3/11.html
We develop an agent-based transport model using a realistic GIS-enabled road network and the car following method. The model can be used to study the impact of social interventions such as flexi-time and workplace sharing, as well as large infrastructure such as the construction of a bypass or highway. The model is developed in Netlogo version 5 and requires road network data in GIS format to run.
Risk perception of individuals and the transmission dynamics of COVID-19
Sara Shahin Moghadam Franziska klügel | Published Tuesday, June 27, 2023The purpose of this model is to explore the influence of integrating individuals’ behavioral dynamics in an agent-based model of COVID-19, on the dynamics of disease transmission. The model is an agent-based extention of an established large-scale Individual-based model called STRIDE. Four risk factors determine the individual’s perception of the risk and how they behave accordingly. It is assumed that individuals with higher levels of risk perception adopt higher levels of contact reduction in their daily routines. Individuals can assign different weights to any of the four different risk factors, i.e., the modeler can model different populations and explore how the transmission dynamics vary among them.
A Model of Iterated Ultimatum game
Andrea Scalco | Published Tuesday, February 24, 2015 | Last modified Monday, March 09, 2015The simulation generates two kinds of agents, whose proposals are generated accordingly to their selfish or selfless behaviour. Then, agents compete in order to increase their portfolio playing the ultimatum game with a random-stranger matching.
Displaying 10 of 321 results for "Martin Lange" clear search