Our mission is to help computational modelers develop, document, and share their computational models in accordance with community standards and good open science and software engineering practices. Model authors can publish their model source code in the Computational Model Library with narrative documentation as well as metadata that supports open science and emerging norms that facilitate software citation, computational reproducibility / frictionless reuse, and interoperability. Model authors can also request private peer review of their computational models. Models that pass peer review receive a DOI once published.
All users of models published in the library must cite model authors when they use and benefit from their code.
Please check out our model publishing tutorial and feel free to contact us if you have any questions or concerns about publishing your model(s) in the Computational Model Library.
Displaying 9 of 29 results for "Carlo Proietti" clear search
Imperfect knowledge and stable governance in democracies
Carlos M Fernández-Márquez Francisco Jose Vazquez Luis Fernando Medina | Published Tuesday, February 05, 2019In this paper we introduce an agent-based model of elections and government formation where voters do not have perfect knowledge about the parties’ ideological position. Although voters are boundedly rational, they are forward-looking in that they try to assess the likely impact of the different parties over the resulting government. Thus, their decision rules combine sincere and strategic voting: they form preferences about the different parties but deem some of them as inadmissible and try to block them from office. We find that the most stable and durable coalition governments emerge at intermediate levels of informational ambiguity. When voters have very poor information about the parties, their votes are scattered too widely, preventing the emergence of robust majorities. But also, voters with highly precise perceptions about the parties will cluster around tiny electoral niches with a similar aggregate effect.
Peer reviewed SWIRS Spread of a woody invader in riparian systems
Moira Zellner Beatriz Sosa Carlos Andrés Chiale | Published Tuesday, May 09, 2023Riparian forests are one of the most vulnerable ecosystems to the development of biological invasions, therefore limiting their spread is one of the main challenges for conservation. The main factors that explain plant invasions in these ecosystems are the capacity for both short- and long-distance seed dispersion, and the occurrence of suitable habitats that facilitate the establishment of the invasive species. Large floods constitute an abiotic filter for invasion.
This model simulates the spatio-temporal spread of the woody invader Gleditsia. triacanthos in the riparian forest of the National Park Esteros de Farrapos e Islas del Río Uruguay, a riparian system in the coast of the Uruguay river (South America). In this model, we represent different environmental conditions for the development of G. triacanthos, long- and short-distance spread of its fruits, and large floods as the main factor of mortality for fruit and early stages.
Field results show that the distribution pattern of this invasive species is limited by establishment, i.e. it spreads locally through the expansion of small areas, and remotely through new invasion foci. This model recreates this dispersion pattern. We use this model to derive management implications to control the spread of G. triacanthos
Eliminating hepatitis C virus as a public health threat among HIV-positive men who have sex with men
Nick Scott Mark Stoove David P Wilson Olivia Keiser Carol El-Hayek Joseph Doyle Margaret Hellard | Published Wednesday, October 12, 2016 | Last modified Sunday, December 16, 2018We compare three model estimates for the time and treatment requirements to eliminate HCV among HIV-positive MSM in Victoria, Australia: a compartmental model; an ABM parametrized by surveillance data; and an ABM with a more heterogeneous population.
Peer reviewed Environmental stochasticity, resource heterogeneity, and the evolution of cooperation
Michaela Starkey Colin Lynch Terry Hunt Carl Lipo | Published Friday, March 14, 2025 | Last modified Wednesday, July 30, 2025The emergence of cooperation in human societies is often linked to environmental constraints, yet the specific conditions that promote cooperative behavior remain an open question. This study examines how resource unpredictability and spatial dispersion influence the evolution of cooperation using an agent-based model (ABM). Our simulations test the effects of rainfall variability and resource distribution on the survival of cooperative and non-cooperative strategies. The results show that cooperation is most likely to emerge when resources are patchy, widely spaced, and rainfall is unpredictable. In these environments, non-cooperators rapidly deplete local resources and face high mortality when forced to migrate between distant patches. In contrast, cooperators—who store and share resources—can better endure extended droughts and irregular resource availability. While rainfall stochasticity alone does not directly select for cooperation, its interaction with resource patchiness and spatial constraints creates conditions where cooperative strategies provide a survival advantage. These findings offer broader insights into how environmental uncertainty shapes social organization in resource-limited settings. By integrating ecological constraints into computational modeling, this study contributes to a deeper understanding of the conditions that drive cooperation across diverse human and animal systems.
SERDUX-MARCIM: agent-based simulation of cyberattack propagation in maritime critical infrastructure
Diego Edison Cabuya Padilla Carlos A Castaneda-Marroquin Daniel Díaz-López | Published Thursday, August 20, 2026SERDUX-MARCIM simulates the propagation of a cyberattack over the computational network of an organization in the maritime sector, at the strategic level of decision-making. It is the instantiation of ABM-MARCIM, the agent-based model of the MARCIM framework for the modeling and simulation of maritime cyberdefense.
Every computational asset of the target organization – servers, endpoints, routers, gateways, vessel systems, radars – is an agent that occupies one of six states at each time step: Susceptible, Exposed, Resistant, Degraded, Unavailable or Destroyed, the initials of which give the model its name. The states Degraded, Unavailable and Destroyed are associated with the D5 cyberattack effects (disrupt, degrade, deny, destroy, deceive) as a function of the degree and the duration of the attack. Thirteen transitions between states are admissible.
Unlike a conventional agent-based model, the local update function is not an individual behavioral rule. It is a system of six ordinary differential equations with eight time-dependent transition rates – propagation, cyberattack (degraded), cyberattack (unavailable), cyberattack (destroyed), recovery, sanitation, loss of resistance, and unavailability by other causes. The values of those rates derive from the capabilities of the target organization, the capabilities of the attacker, and the degree and duration of the cyberattack, computed through a cyber risk approach aligned with the OWASP Risk Rating Methodology, the ISACA categorization of security controls and the IMO Guidelines on Maritime Cyber Risk Management.
…
Peer reviewed Agent-Based Ramsey growth model with Brown and Green capital (ABRam-BG)
Sarah Wolf Aida Sarai Figueroa Alvarez | Published Monday, December 09, 2024The purpose of the ABRam-BG model is to study belief dynamics as a potential driver of green (growth) transitions and illustrate their dynamics in a closed, decentralized economy populated by utility maximizing agents with an environmental attitude. The model is built using the ABRam-T model (for model visit: https://doi.org/10.25937/ep45-k084) and introduces two types of capital – green (low carbon intensity) and brown (high carbon intensity) – with their respective technological progress levels. ABRam-BG simulates a green transition as an emergent phenomenon resulting from well-known opinion dynamics along the economic process.
Wave When the Hale Wale (WWHW)
María Pereda José Manuel Galán Iván Briz I Godino Jorge Caro Débora Zurro Myriam Álvarez José Santos | Published Friday, October 10, 2014 | Last modified Wednesday, April 25, 2018WWHW is an agent-based model designed to allow the exploration of the emergence, resilience and evolution of cooperative behaviours in hunter-fisher-gatherer societies.
Peer reviewed Agent-Based Ramsey growth model with endogenous technical progress (ABRam-T)
Sarah Wolf Aida Sarai Figueroa Alvarez Malika Tokpanova | Published Wednesday, February 14, 2024 | Last modified Monday, February 19, 2024The Agent-Based Ramsey growth model is designed to analyze and test a decentralized economy composed of utility maximizing agents, with a particular focus on understanding the growth dynamics of the system. We consider farms that adopt different investment strategies based on the information available to them. The model is built upon the well-known Ramsey growth model, with the introduction of endogenous technical progress through mechanisms of learning by doing and knowledge spillovers.
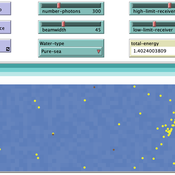
ABM for Underwater optical wireless communication in a water tank
Mohamed ABID | Published Sunday, May 29, 2022This model simulates the propagation of photons in a water tank. A source of light emits an impulse of photons with equal energy represented by yellow dots. These photons are then scattered by water particles before possibly reaching the photo-detector represented by a gray line. Different types of water are considered. For each one of them we calculate the total received energy.
The water tank is represented by a blue rectangle with fixed dimensions. It’s exposed to the air interface and has totally absorbent barriers. Four types of water are supported. Each one is characterized by its absorption and scattering coefficients.
At the source, the photons are generated uniformly with a random direction within the beamwidth. Each photon travels a random distance drawn from a distribution depending on the water characteristics before encountering a water particle.
Based on the updated position of the photon, three situations may occur:
-The photon hits the barrier of the tank on its trajectory. In this case it’s considered as lost since the barriers are assumed totally absorbent.
…
Displaying 9 of 29 results for "Carlo Proietti" clear search