Our mission is to help computational modelers develop, document, and share their computational models in accordance with community standards and good open science and software engineering practices. Model authors can publish their model source code in the Computational Model Library with narrative documentation as well as metadata that supports open science and emerging norms that facilitate software citation, computational reproducibility / frictionless reuse, and interoperability. Model authors can also request private peer review of their computational models. Models that pass peer review receive a DOI once published.
All users of models published in the library must cite model authors when they use and benefit from their code.
Please check out our model publishing tutorial and feel free to contact us if you have any questions or concerns about publishing your model(s) in the Computational Model Library.
Displaying 10 of 64 results movement clear search
Random Vs Expert movement simulation for different bird groups in Bogota, Colombia
Martin Otalora-Low | Published Thursday, November 05, 2026The model’s primary aim was not to be entirely realistic; instead, it was designed to point to new questions, test the usefulness of the tool, and lay the groundwork for new insights. As such, this model is targeted at ecologists, ornithologists, and urban planners who want to test and simulate how different birds face the challenge of a densely urbanized city that aims to enhance its natural connectivity and foster a wide range of biodiversity. We aimed to identify bird movement at the city-wide scale, encompassing representatives from the entire avian community, while examining differences in movement between totally random models and an informed model, defined by expert criteria.
Essential Workers at Risk: An Agent-Based Model (SAFE-ABM) with Uncertainty Quantification
Elizabeth Amona Edward L Boone | Published Sunday, November 01, 2026This archive contains the SAFE-ABM computational model developed to evaluate targeted intervention strategies for protecting essential workers during epidemic conditions, accompanying the published article “Essential Workers at Risk: An Agent-Based Model (SAFE-ABM) with Uncertainty Quantification” in the Journal of Artificial Societies and Social Simulation, 29(4), Article 7 (2026). https://doi.org/10.18564/jasss.6276. SAFE-ABM is an agent-based model that simulates disease transmission through structured interactions across households, workplaces, and schools, while incorporating stochastic disease progression and uncertainty in transmission, recovery, and mortality parameters.
The model evaluates five intervention scenarios: Scenario 1, no restrictions; Scenario 2, school-from-home; Scenario 3, essential-workers-only movement; Scenario 4, rotational shifts among essential workers with quarantine of symptomatic active workers; and Scenario 5, rotational shifts among essential workers without quarantine. The archive includes scenario-specific simulation scripts, comparison-analysis scripts, saved derived outputs, README documentation, software requirements, and reproducibility notes.
The included comparison scripts reproduce the main numerical summaries and manuscript outputs, including median epidemic trajectories, predictive-uncertainty plots, cumulative recovery and death summaries, inflection-point summaries, Welch-test comparisons, and mutual-information sensitivity rankings. Saved derived outputs are included so that the main figures and tables can be reproduced without rerunning all large-scale simulations.
…
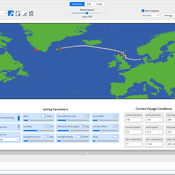
Viking Sailing: Simulation of Viking era small ship sailing
C Michael Barton | Published Wednesday, October 07, 2026Viking Sailing is a spatially explicit agent-based simulation for conditional exploration of how rasterized coastlines, wind, and
surface-current conditions interact with simplified ship movement, sailing, rowing, navigation, and land-avoidance rules. The
model compares simulated route trajectories and terminal outcomes for hypothetical Viking-era small-ship voyages. It includes an example dataset representing sea surface winds and currents from June 1000 CE. Additional data can are downloaded from Zenodo: https://zenodo.org/records/23213147.
Peer reviewed Agent-Based Model of Avian Movement and Functional Connectivity in Bogotá: Evaluating the 'Media Luna del Sur' Ecological Corridor (POT 2022–2035)
Maria Emilia Pelaez De Los Rios | Published Monday, September 14, 2026This NetLogo model simulates the movement and foraging behavior of 20 bird species (classified as urban avoiders or utilizers) across a 20×20m grid landscape representing southern Bogotá, Colombia. Agents follow an optimal foraging strategy (90% of the time) or move randomly (10%), gaining energy from land-cover-dependent food sources and dying if energy falls below their basal metabolic rate. The model compares two landscape scenarios — current land cover (2016) and a proposed scenario incorporating the ‘Media Luna del Sur’ ecological corridor from Bogotá’s 2022–2035 Land Use Plan (POT) — to evaluate whether the proposed green infrastructure improves functional connectivity for avian biodiversity across the urban matrix. Outputs include cumulative patch visitation counts, exported as raster files, used to generate connectivity heatmaps.
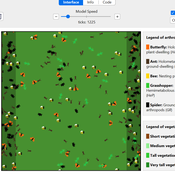
Modelling the effects of mowing regimes on arthropod abundance in grasslands of Lüneburg
Johanna Augustin Joanna-173 | Published Tuesday, August 25, 2026This NetLogo model simulates the impact of mowing frequency, mower type and the percentage of refuge strips on the abundance of arthropods in managed grasslands. It represents five functional arthropod groups: holometabolous plant-dwelling arthropods (HoP, represented by butterflies); holometabolous ground-dwelling arthropods (HoG, represented by ants); nesting pollinators (NP, represented by bees); hemimetabolous plant-dwelling arthropods (HeP, represented by grasshoppers); and ground-resident arthropods (GR, represented by spiders). Three mowing frequencies are simulated: intensive (four mowings per year), intermediate (two mowings per year) and extensive (one mowing per year). Bar and disc mowers differ in their effects on arthropod mortality and vegetation height. Refuge strip coverage can be set to 0%, 10% or 20%. Arthropod abundance changes over time through movement, reproduction, natural mortality, mower-related mortality and vegetation regrowth.
Agent modeling (ABM) as a tool to improve the mobility of “avoidant” birds in an ecological corridor in the localities of Chapinero, Teusaquillo, Barrios Unidos and Engativá of Bogotá city [Scenario 2]
Paula Alejandra Meza | Published Thursday, June 25, 2026Considering that two of the three avoider species could not reach the target area in the inittial scenario, five alternative corridor scenarios were created. In all cases, we generated a greater amount of cover area under ‘Urban forest’, including elements such as scattered trees, woody plants, wooded areas, and rows of trees. This covered type was selected since all three species use it as a regular habitat. That is the second sceneario where those ecological parks and other areas inside the capital city were boostered into “urban forest patches” or buffer points, with the idea of improving the survive of the three bird species and their movement. However one of the most restrictive specie was still having movement and survival issues.
Agent modeling (ABM) as a tool to improve the mobility of “avoidant” birds in an ecological corridor in the localities of Chapinero, Teusaquillo, Barrios Unidos and Engativá of Bogotá city
Paula Alejandra Meza Maria Angela Echeverry-Galvis Mauricio González Méndez | Published Wednesday, June 24, 2026The purpose of this model is to analyze different configurations and scenarios of ecological corridors to simulate the movement of three avoider bird species at a local scale: Chondrohierax uncinatus (Accipitridae), a large carnivorous bird; Ampelion rubrocristatus (Cotingidae), a species that seeks areas with substantial land cover for refuge and rest; and Coeligena bonapartei (Trochilidae), a large hummingbird that prefers areas with a rich and diverse food supply. The model focusses on juvenile bird individuals seeking refuge and food, taking into account the mobility parameters of each species and the existing land cover types within the study area.
Specifically, the model aims to:
• Simulate the movement of 45 avoiders birds which are considered umbrella species sensitive to urban changes (which were chosen based on their specific biological and ecological requirements and parameters relevant to urban conservation efforts), 15 avoiders birds per specie to cross a two-dimensional world predominant urban.
• To be able to select which corridor scenario would be the most beneficial, in order to help the mobility of other species affected by urban fragmentation.
• Contribute to urban ecology research and support decision-making processes by relevant stakeholders.
Aquarium
Yunshuo Tang | Published Tuesday, May 26, 2026This model simulates a simple aquatic ecosystem containing fish and food. It explores how individual interactions such as movement, feeding, and reproduction shape the population dynamics of fish over time.
Peer reviewed Gradient Descent Simulation
Ilyes Azouani | Published Wednesday, March 18, 2026 | Last modified Monday, May 25, 2026This model visualizes gradient descent optimization - the fundamental algorithm used to train neural networks and other machine learning models. Agents represent different optimization algorithms searching for the minimum of a loss landscape (the “error surface” that ML models try to minimize during training).
The model demonstrates how different optimizer types (SGD, Momentum with different parameters) behave on various loss landscapes, from simple bowls to the notoriously difficult Rosenbrock “banana valley” function. This helps build intuition about why certain optimization algorithms work better than others for different problem geometries.
HOW IT WORKS
…
Exploring the aftermath of transition failures: An agent-based model
Junmin Lee Gangmin Park Jisoo Lee Keungoui Kim | Published Friday, March 06, 2026This computational model is an agent-based model (ABM) developed to investigate how repeated failures of emerging niches accumulate and influence the trajectory of socio-technical transitions. Built in AnyLogic 8.7.11, the model simulates the dynamic interactions between a dominant regime and sequential niche entrants within a two-dimensional practice space. It models alignment, movement, and competition based on technological maturity and market penetration. The model utilizes a reinforcing feedback structure linking consumer support, output, resource accumulation, and capacity development (Physical and Institutional Capacity). A complete model specification following the ODD+D (Overview, Design concepts, Details, and Decision) protocol is included in the documentation.
Displaying 10 of 64 results movement clear search